Site under construction — check back daily for updates
Design-Build
Robot Made 2025 · U of T
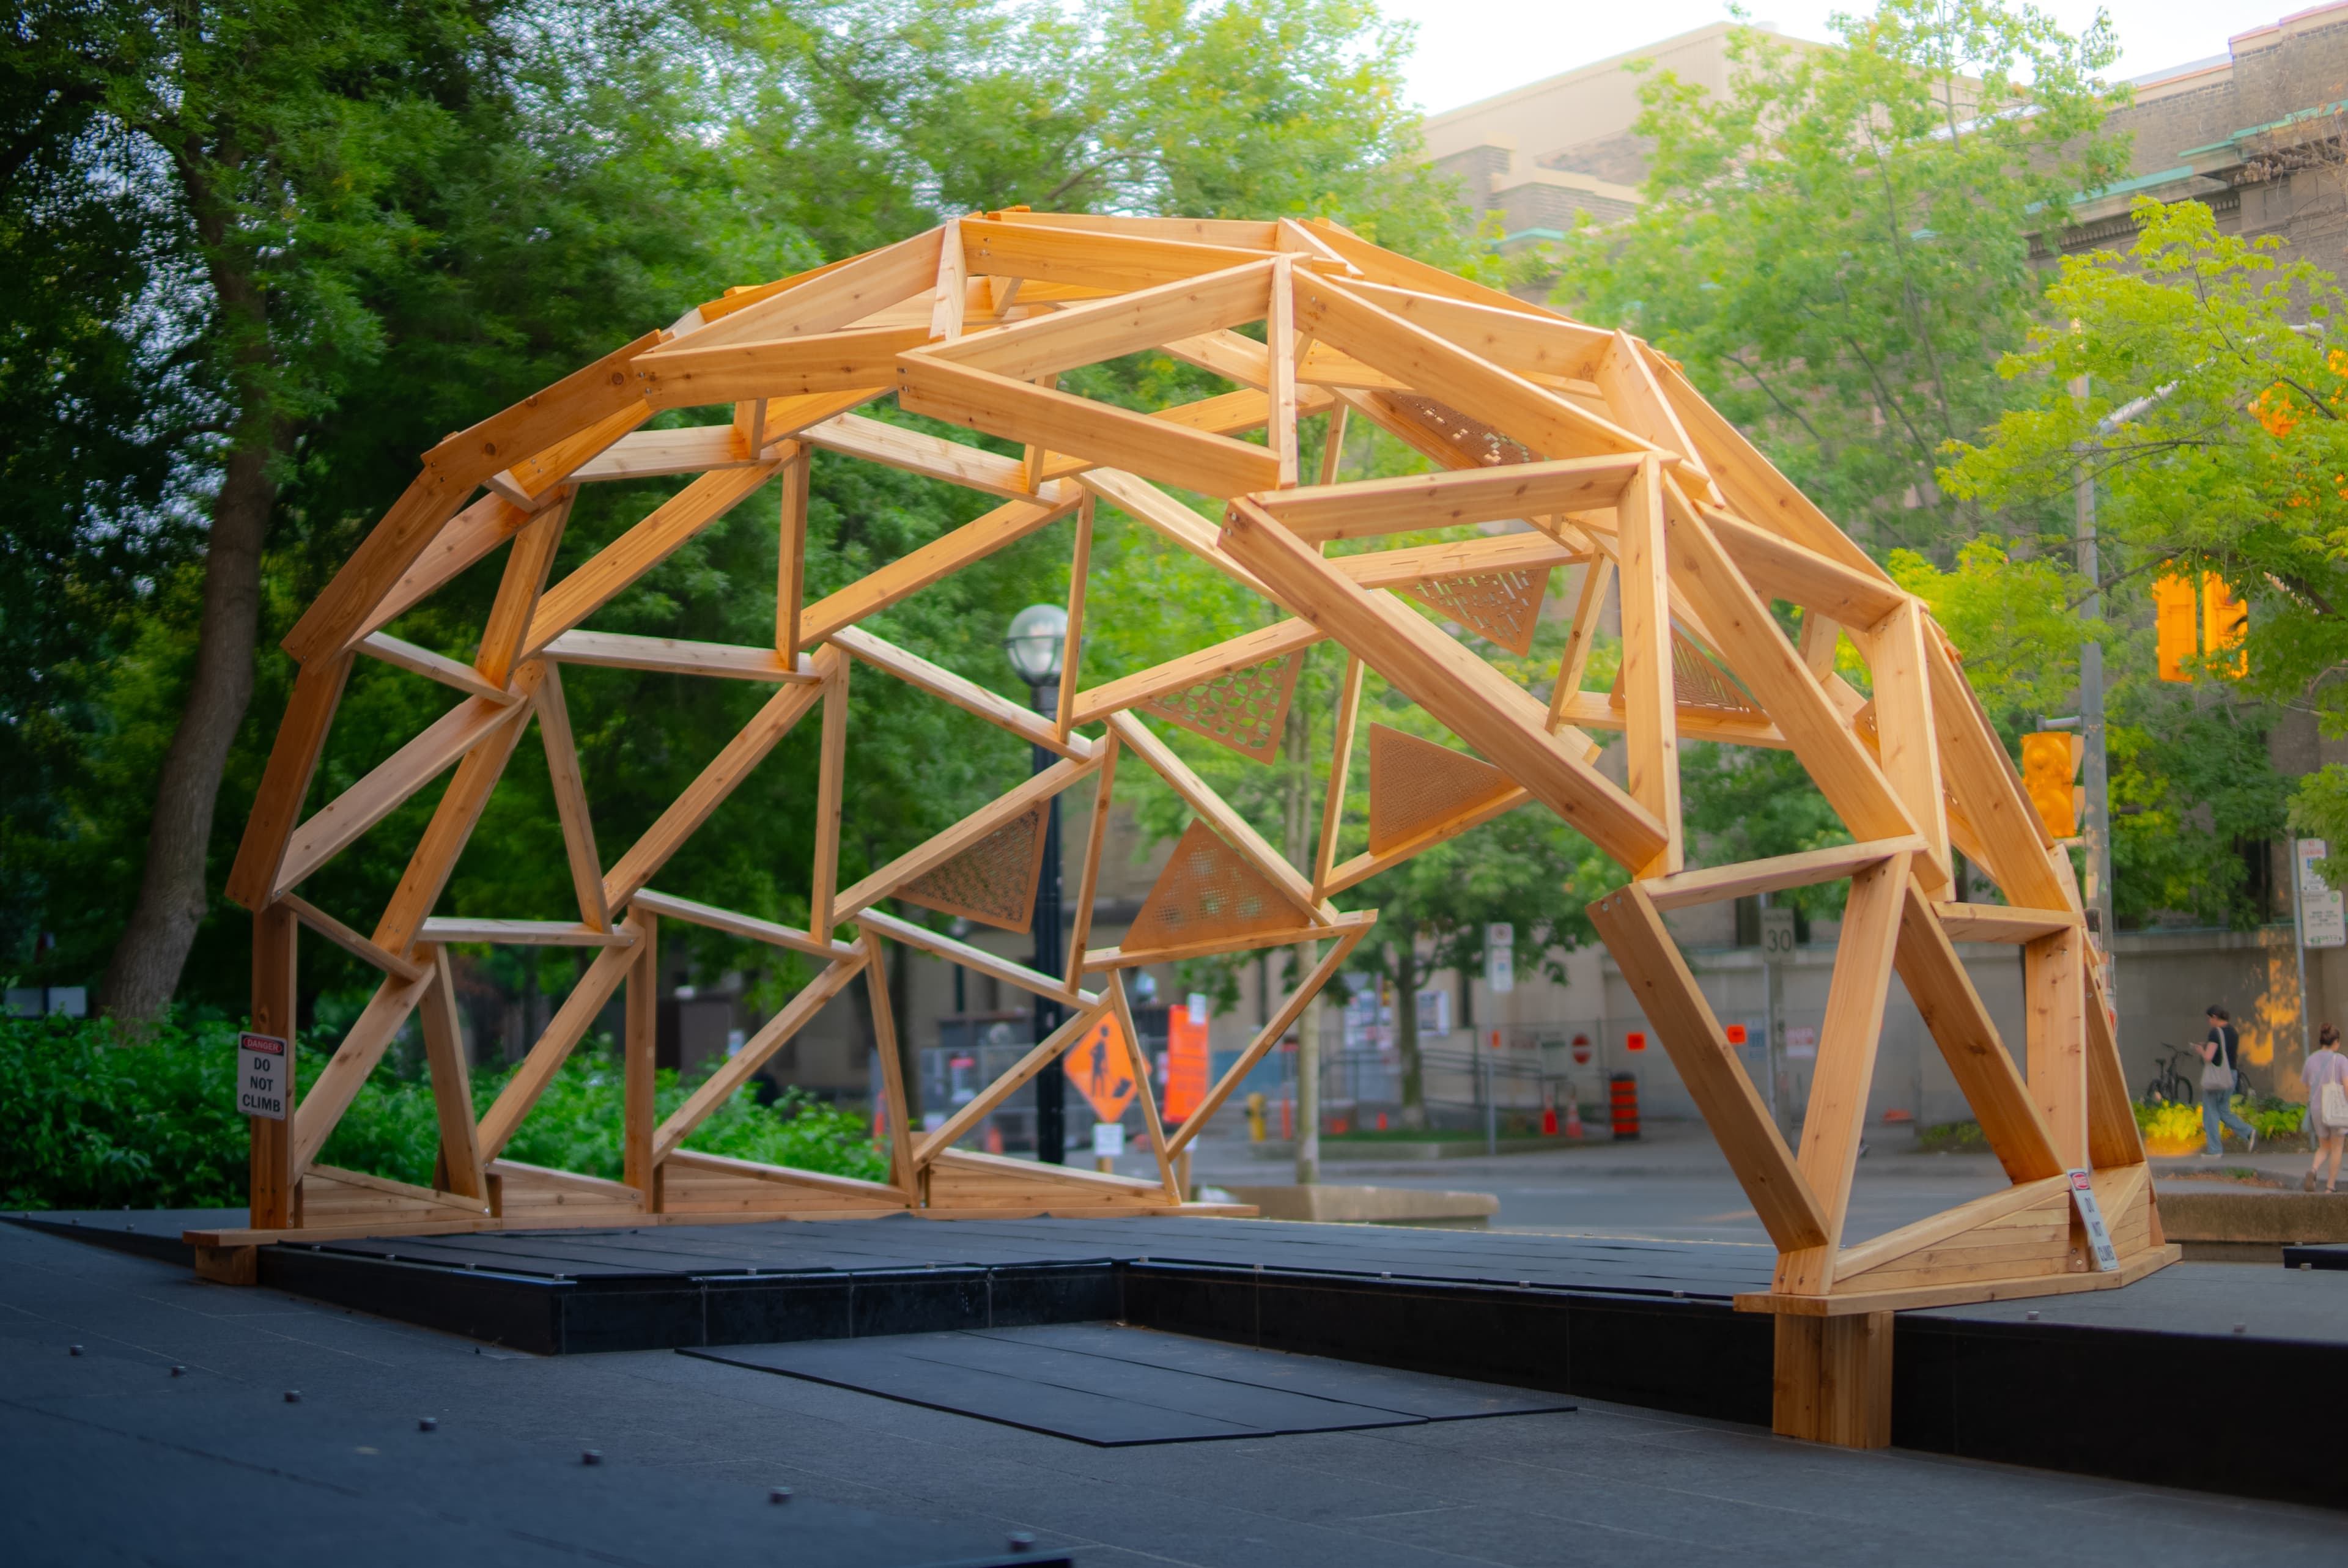
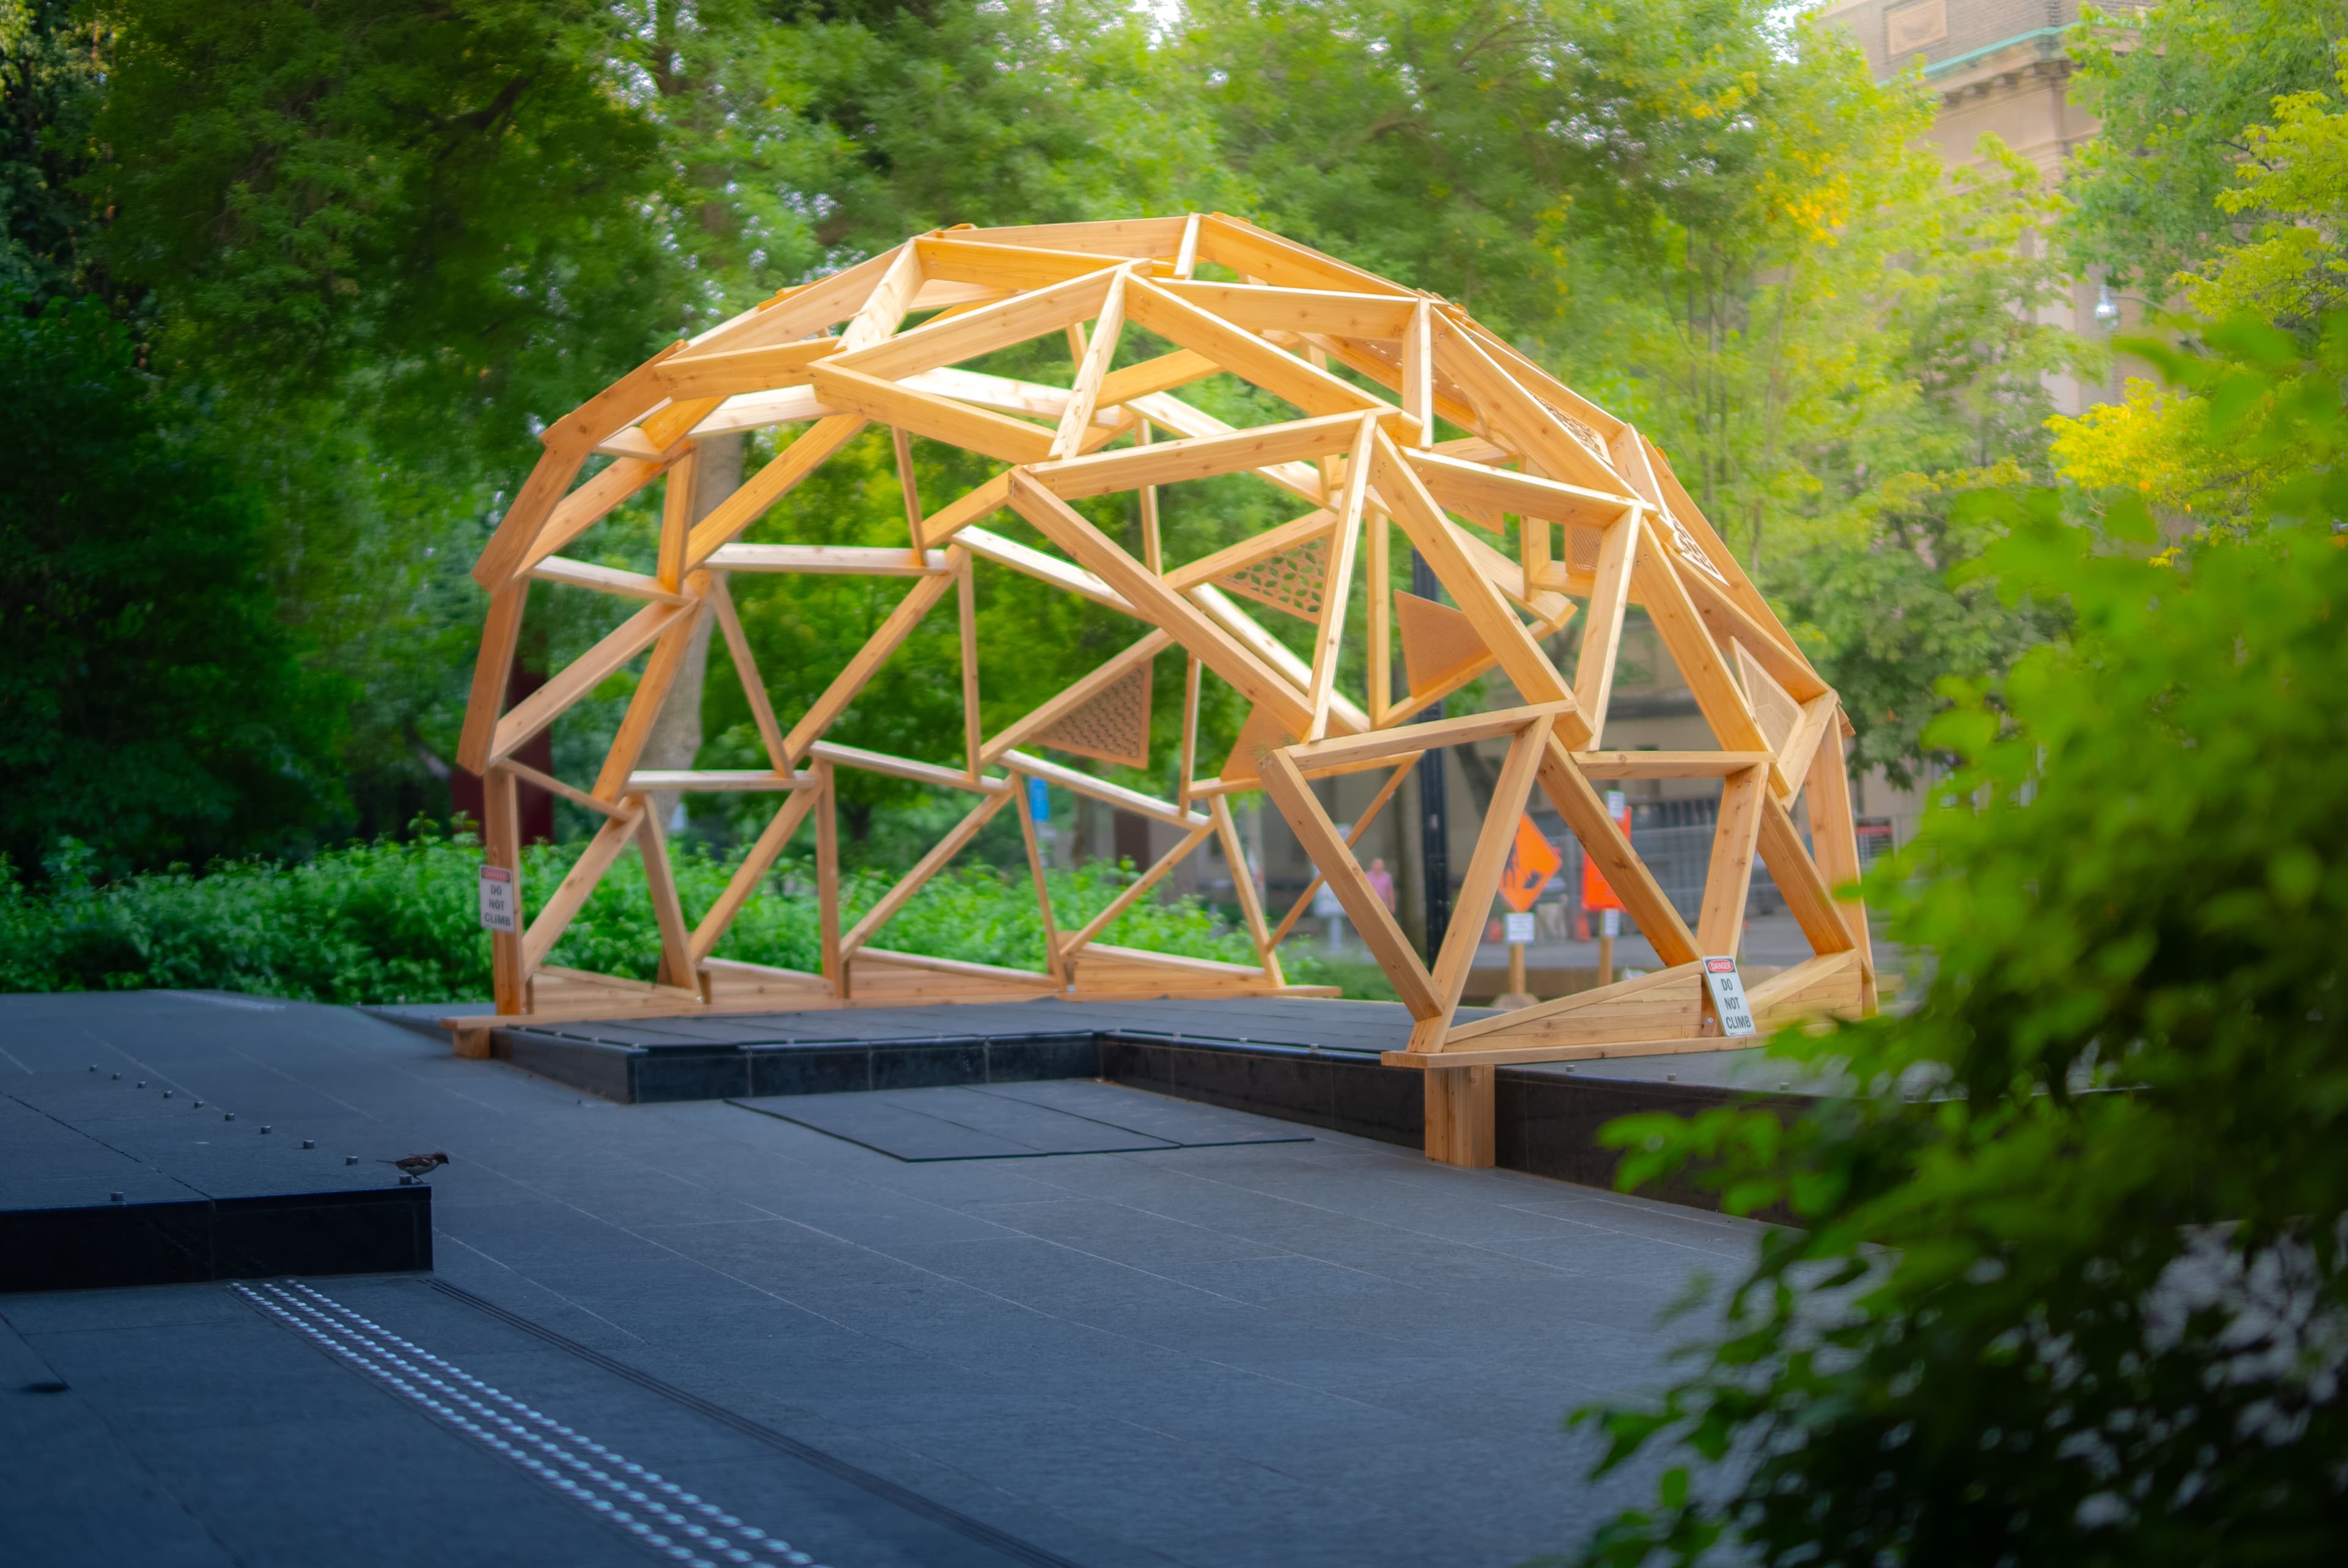
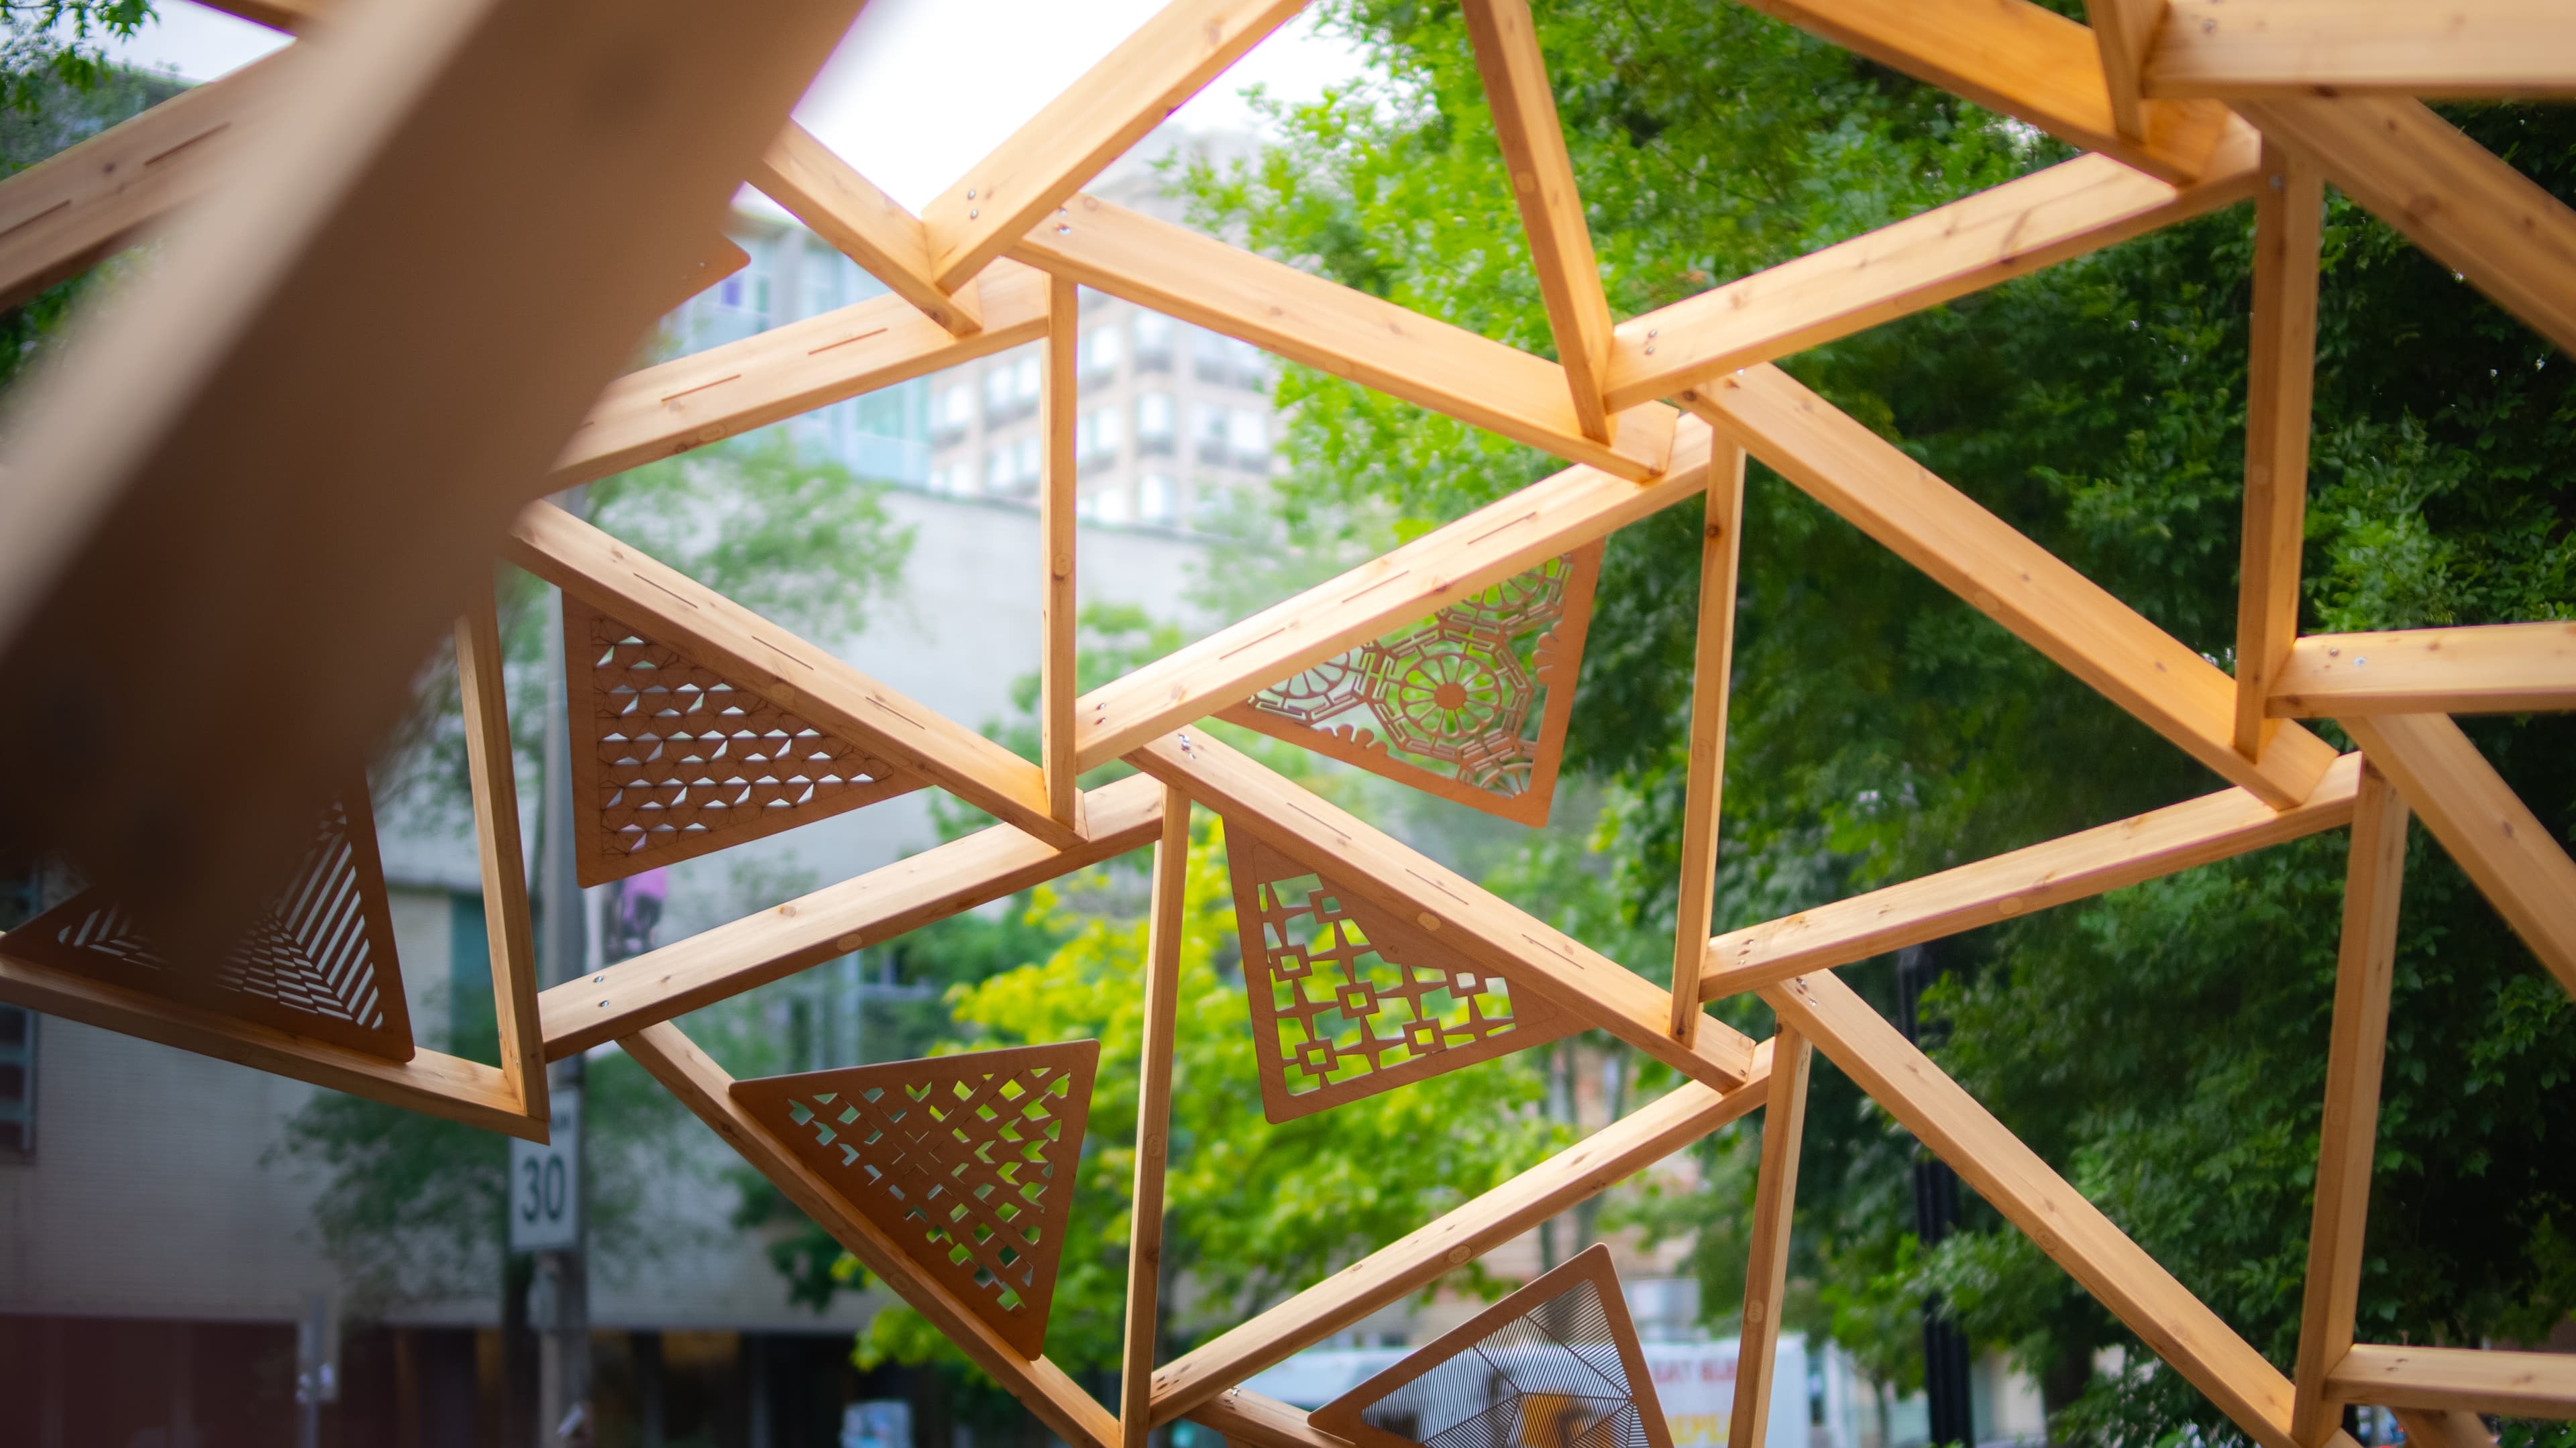
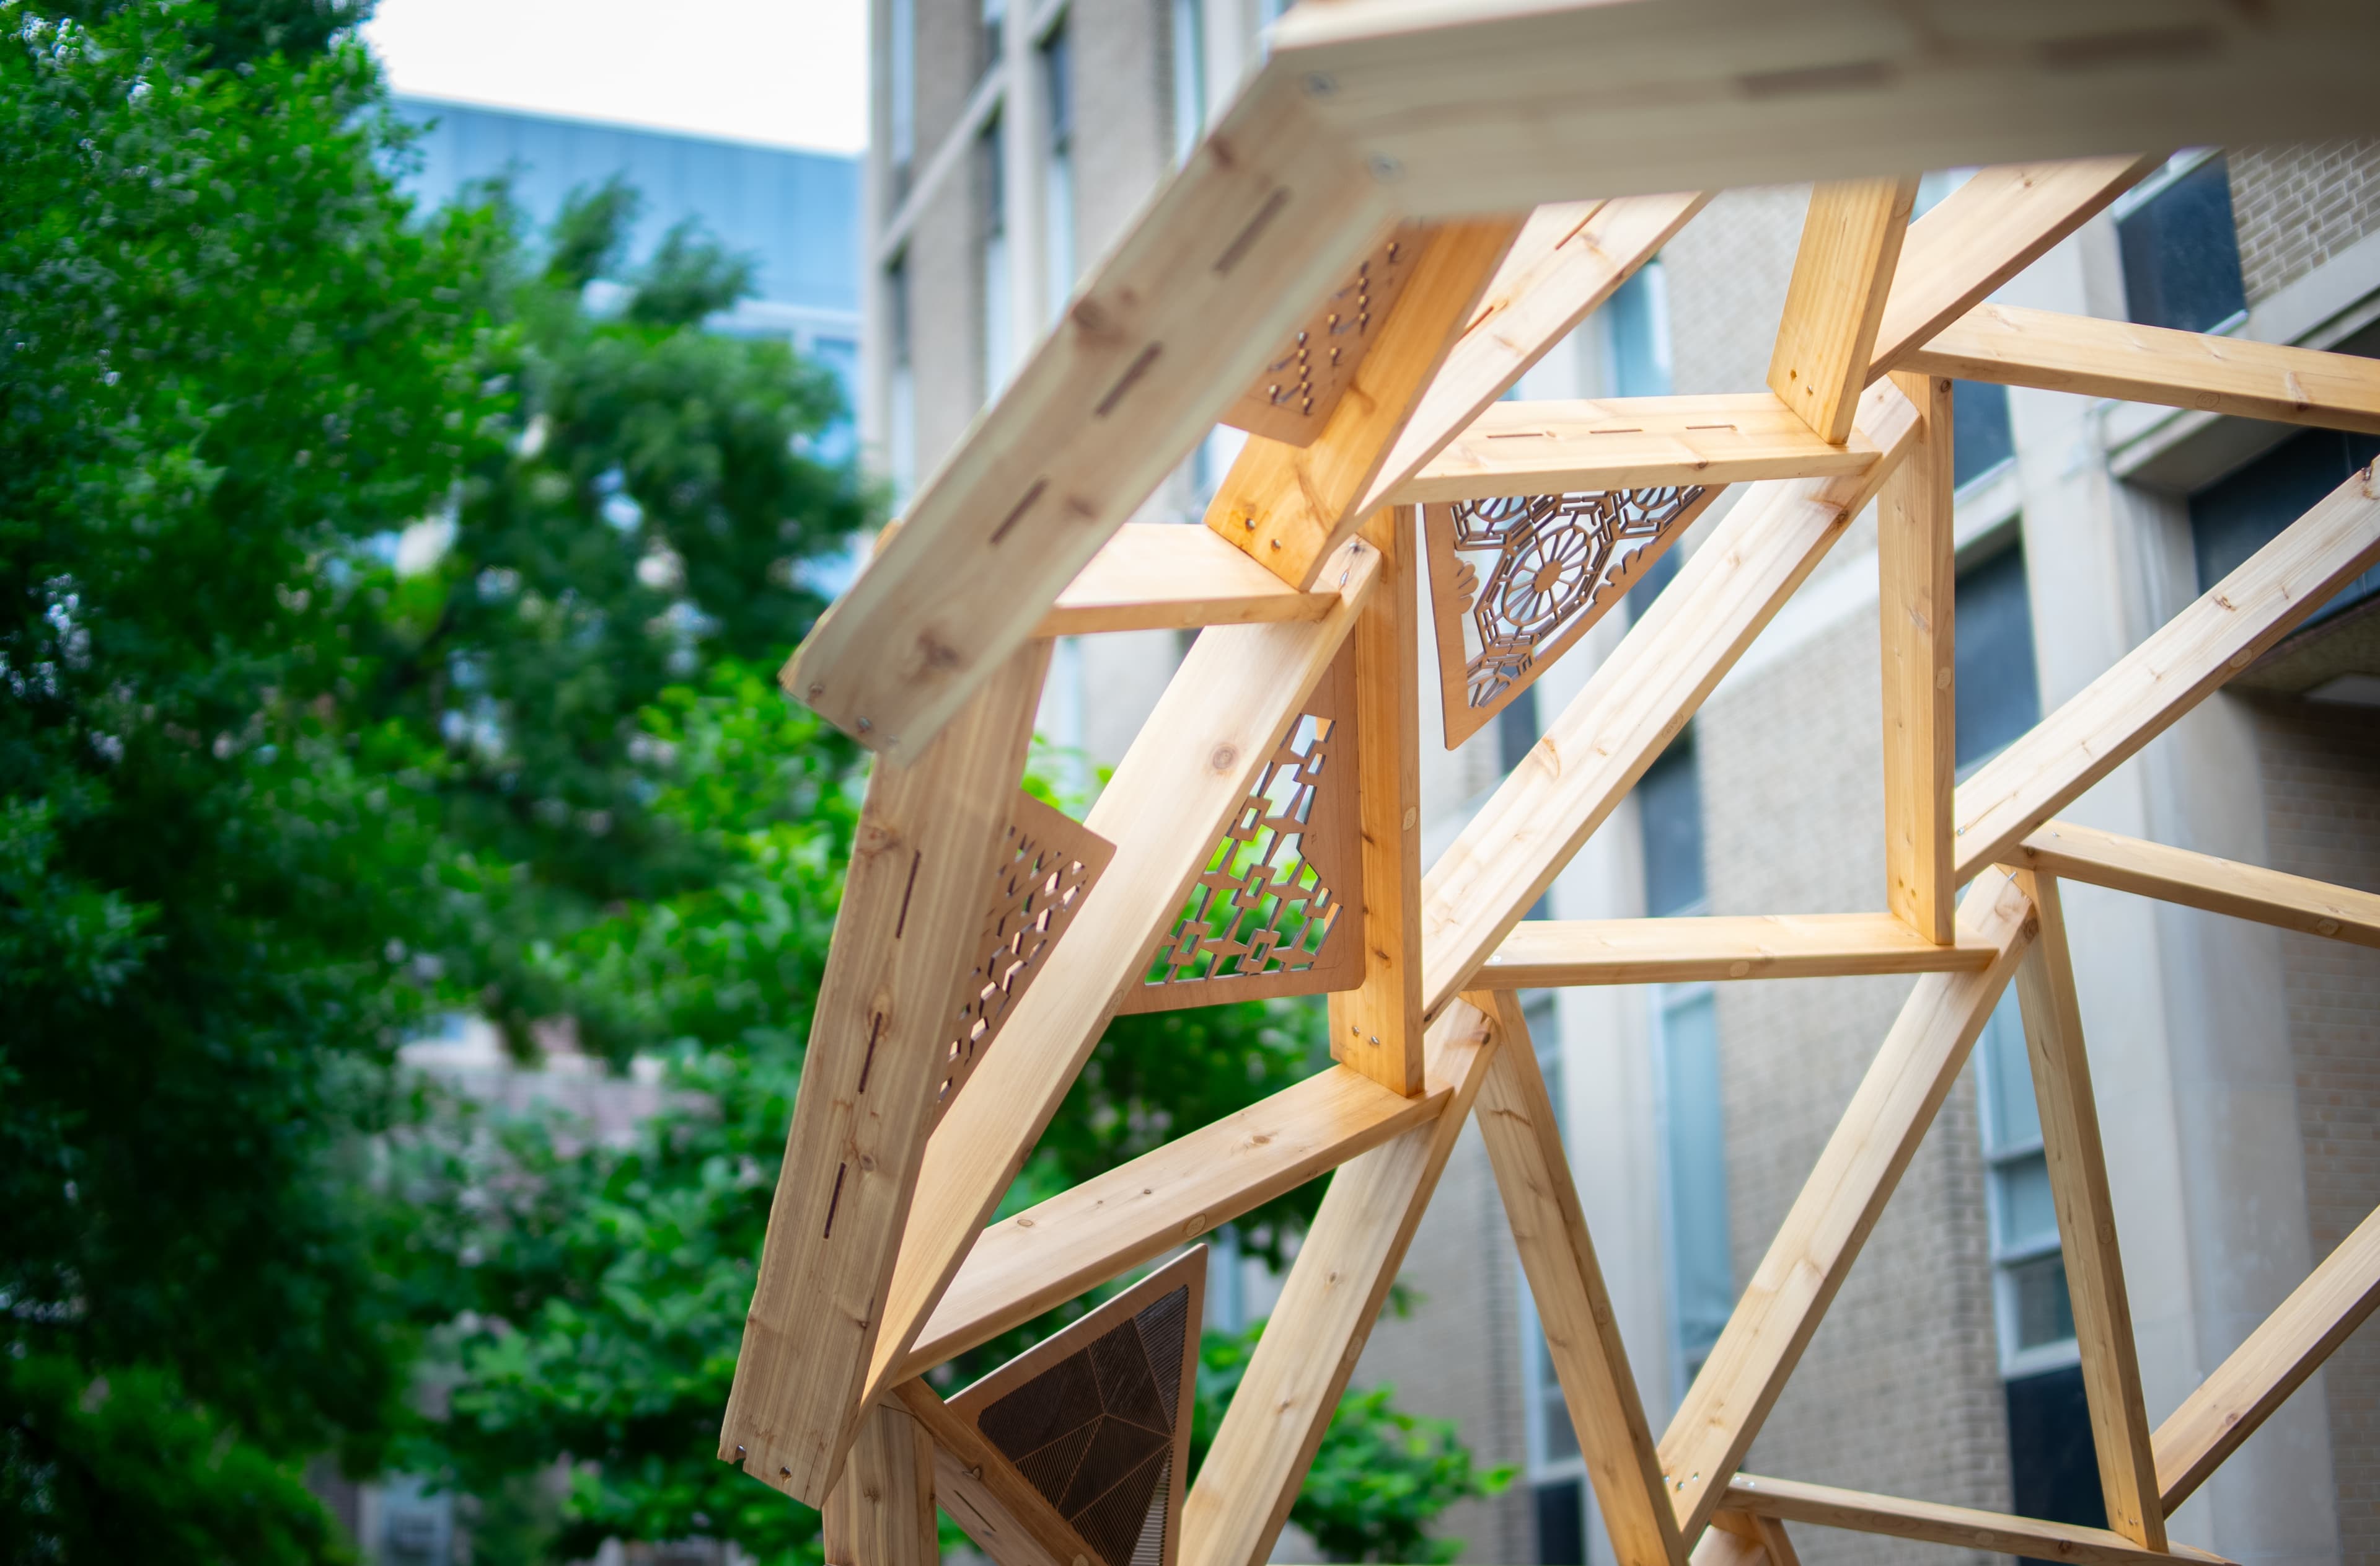
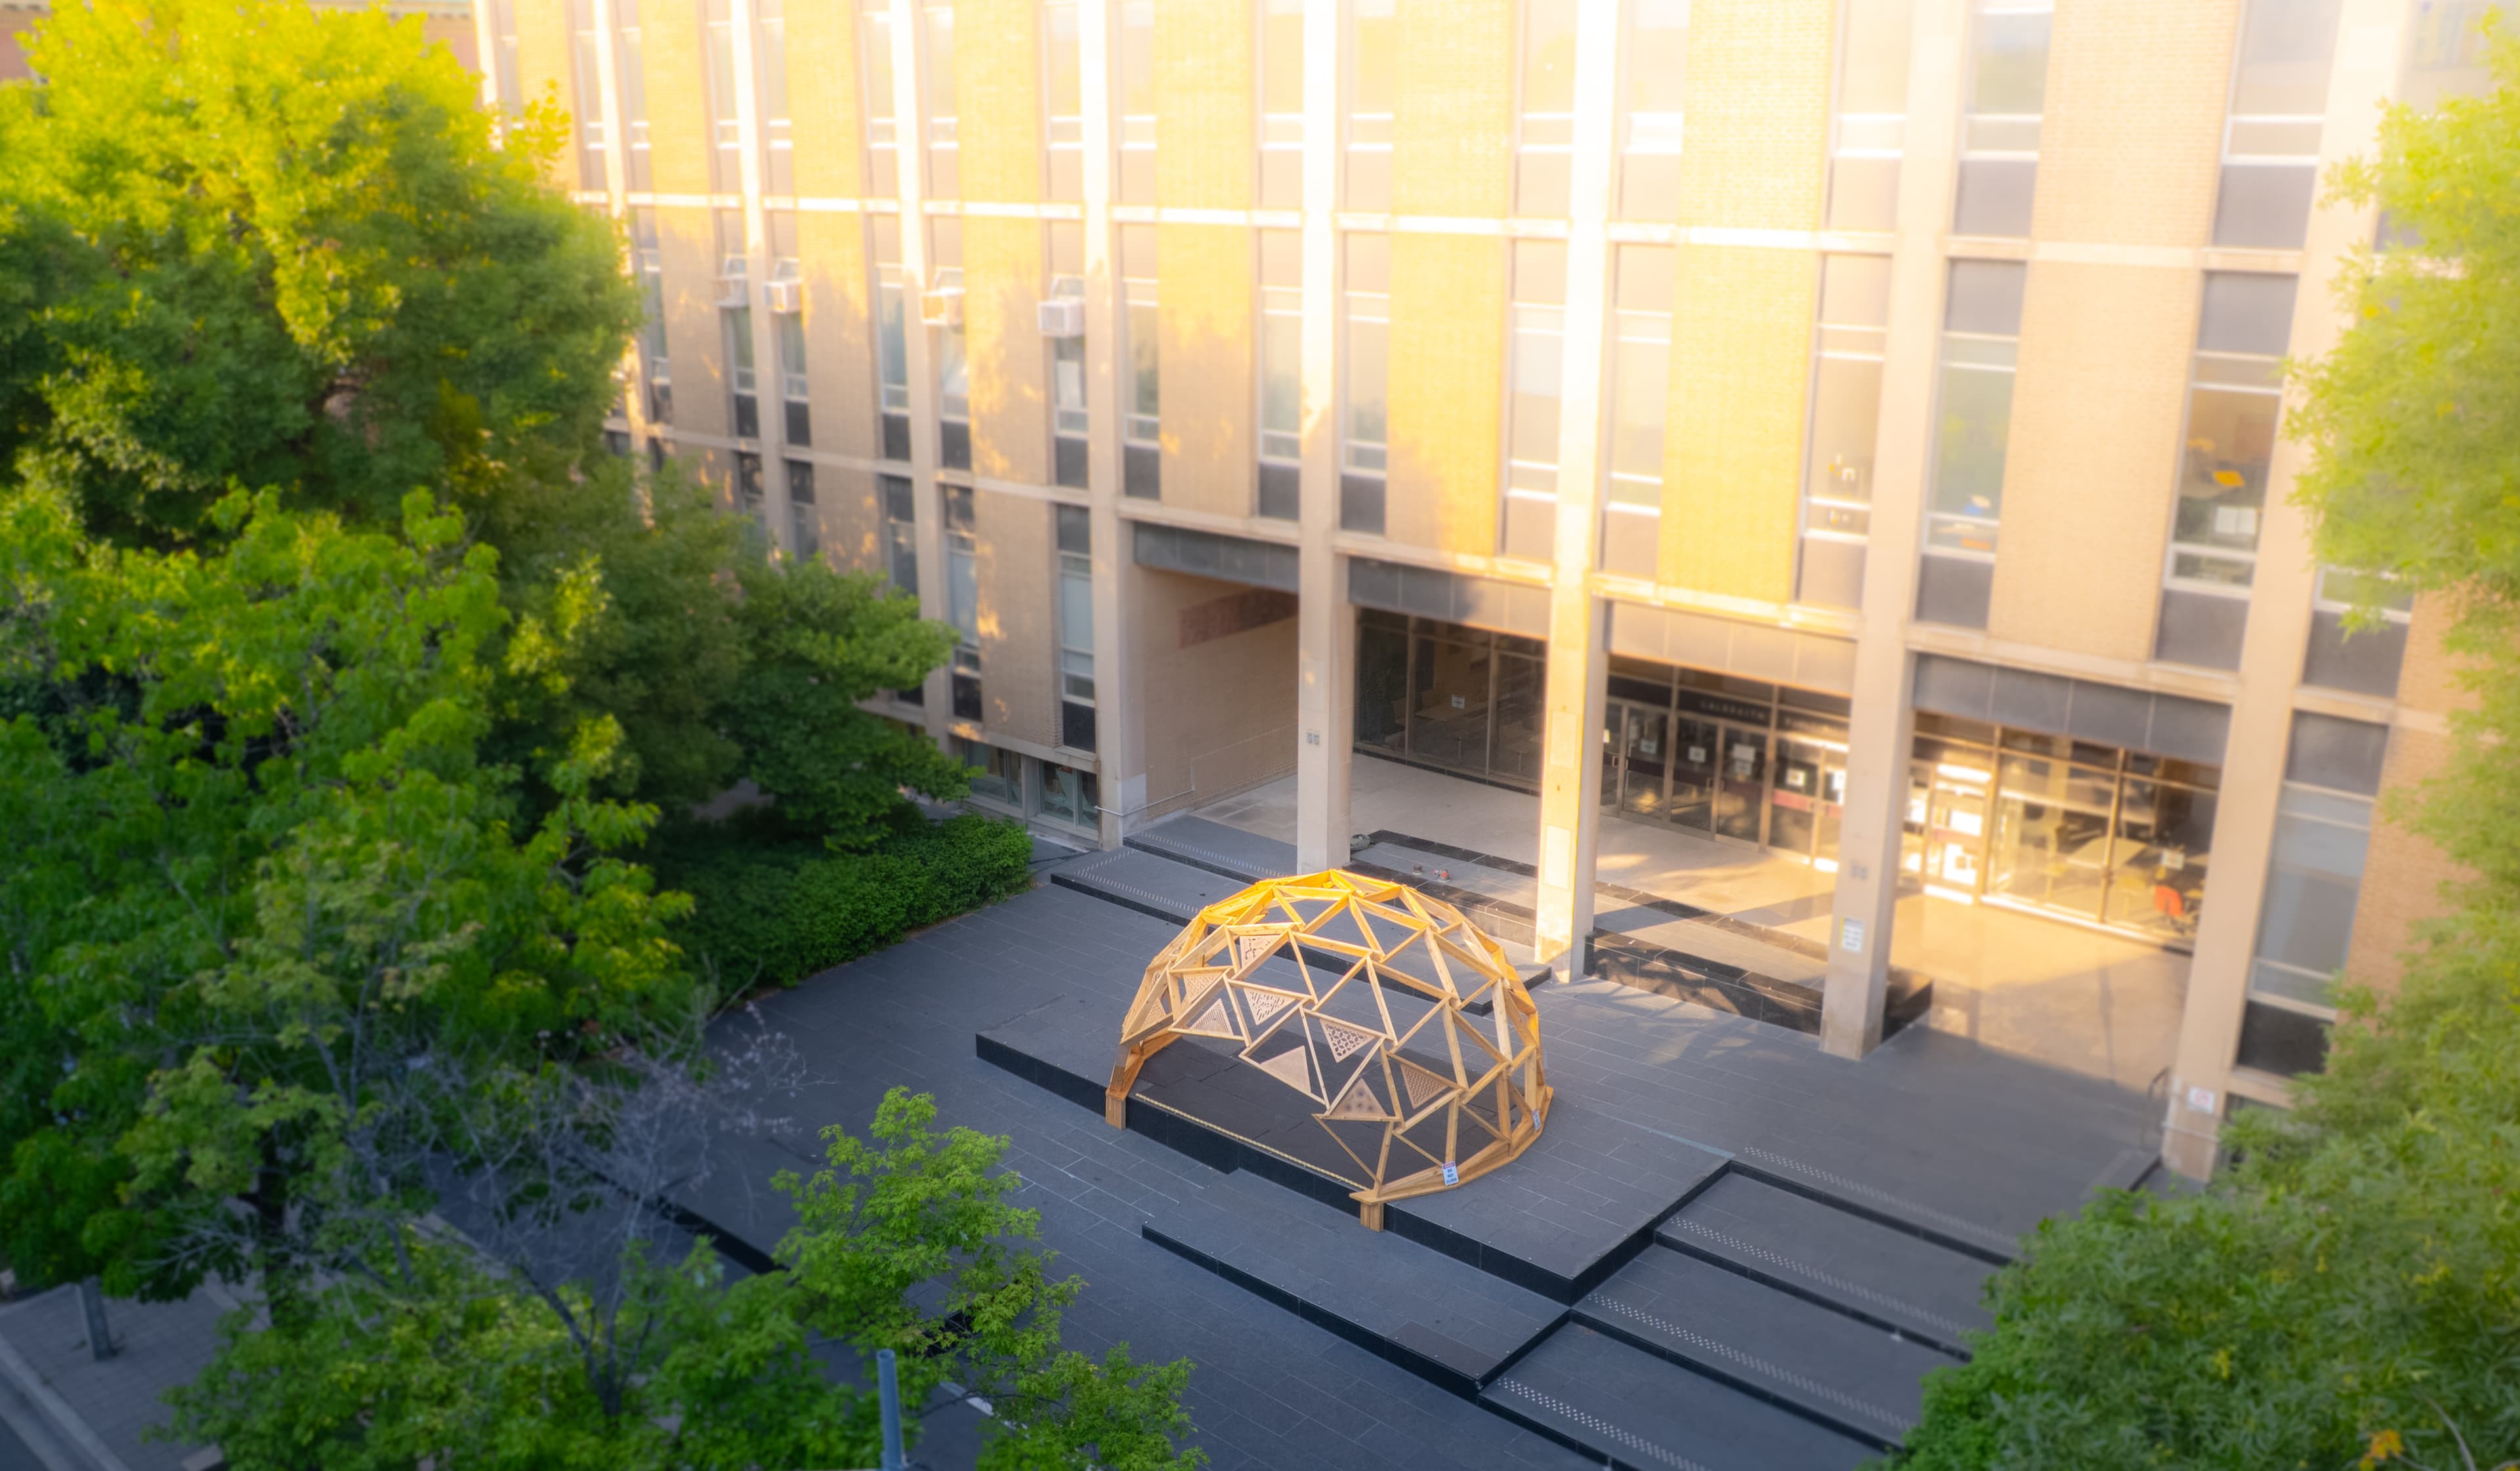
A full-scale reciprocal timber pavilion developed through computational design, robotic fabrication, and rapid collaborative assembly.
Type
Design-Build
Program
Robot Made
Institution
University of Toronto
Year
2025
Role
Teaching Assistant
01
Project Overview
Robot Made 2025 investigated how reciprocal timber structures could be designed, fabricated, and assembled through an integrated computational and robotic workflow.
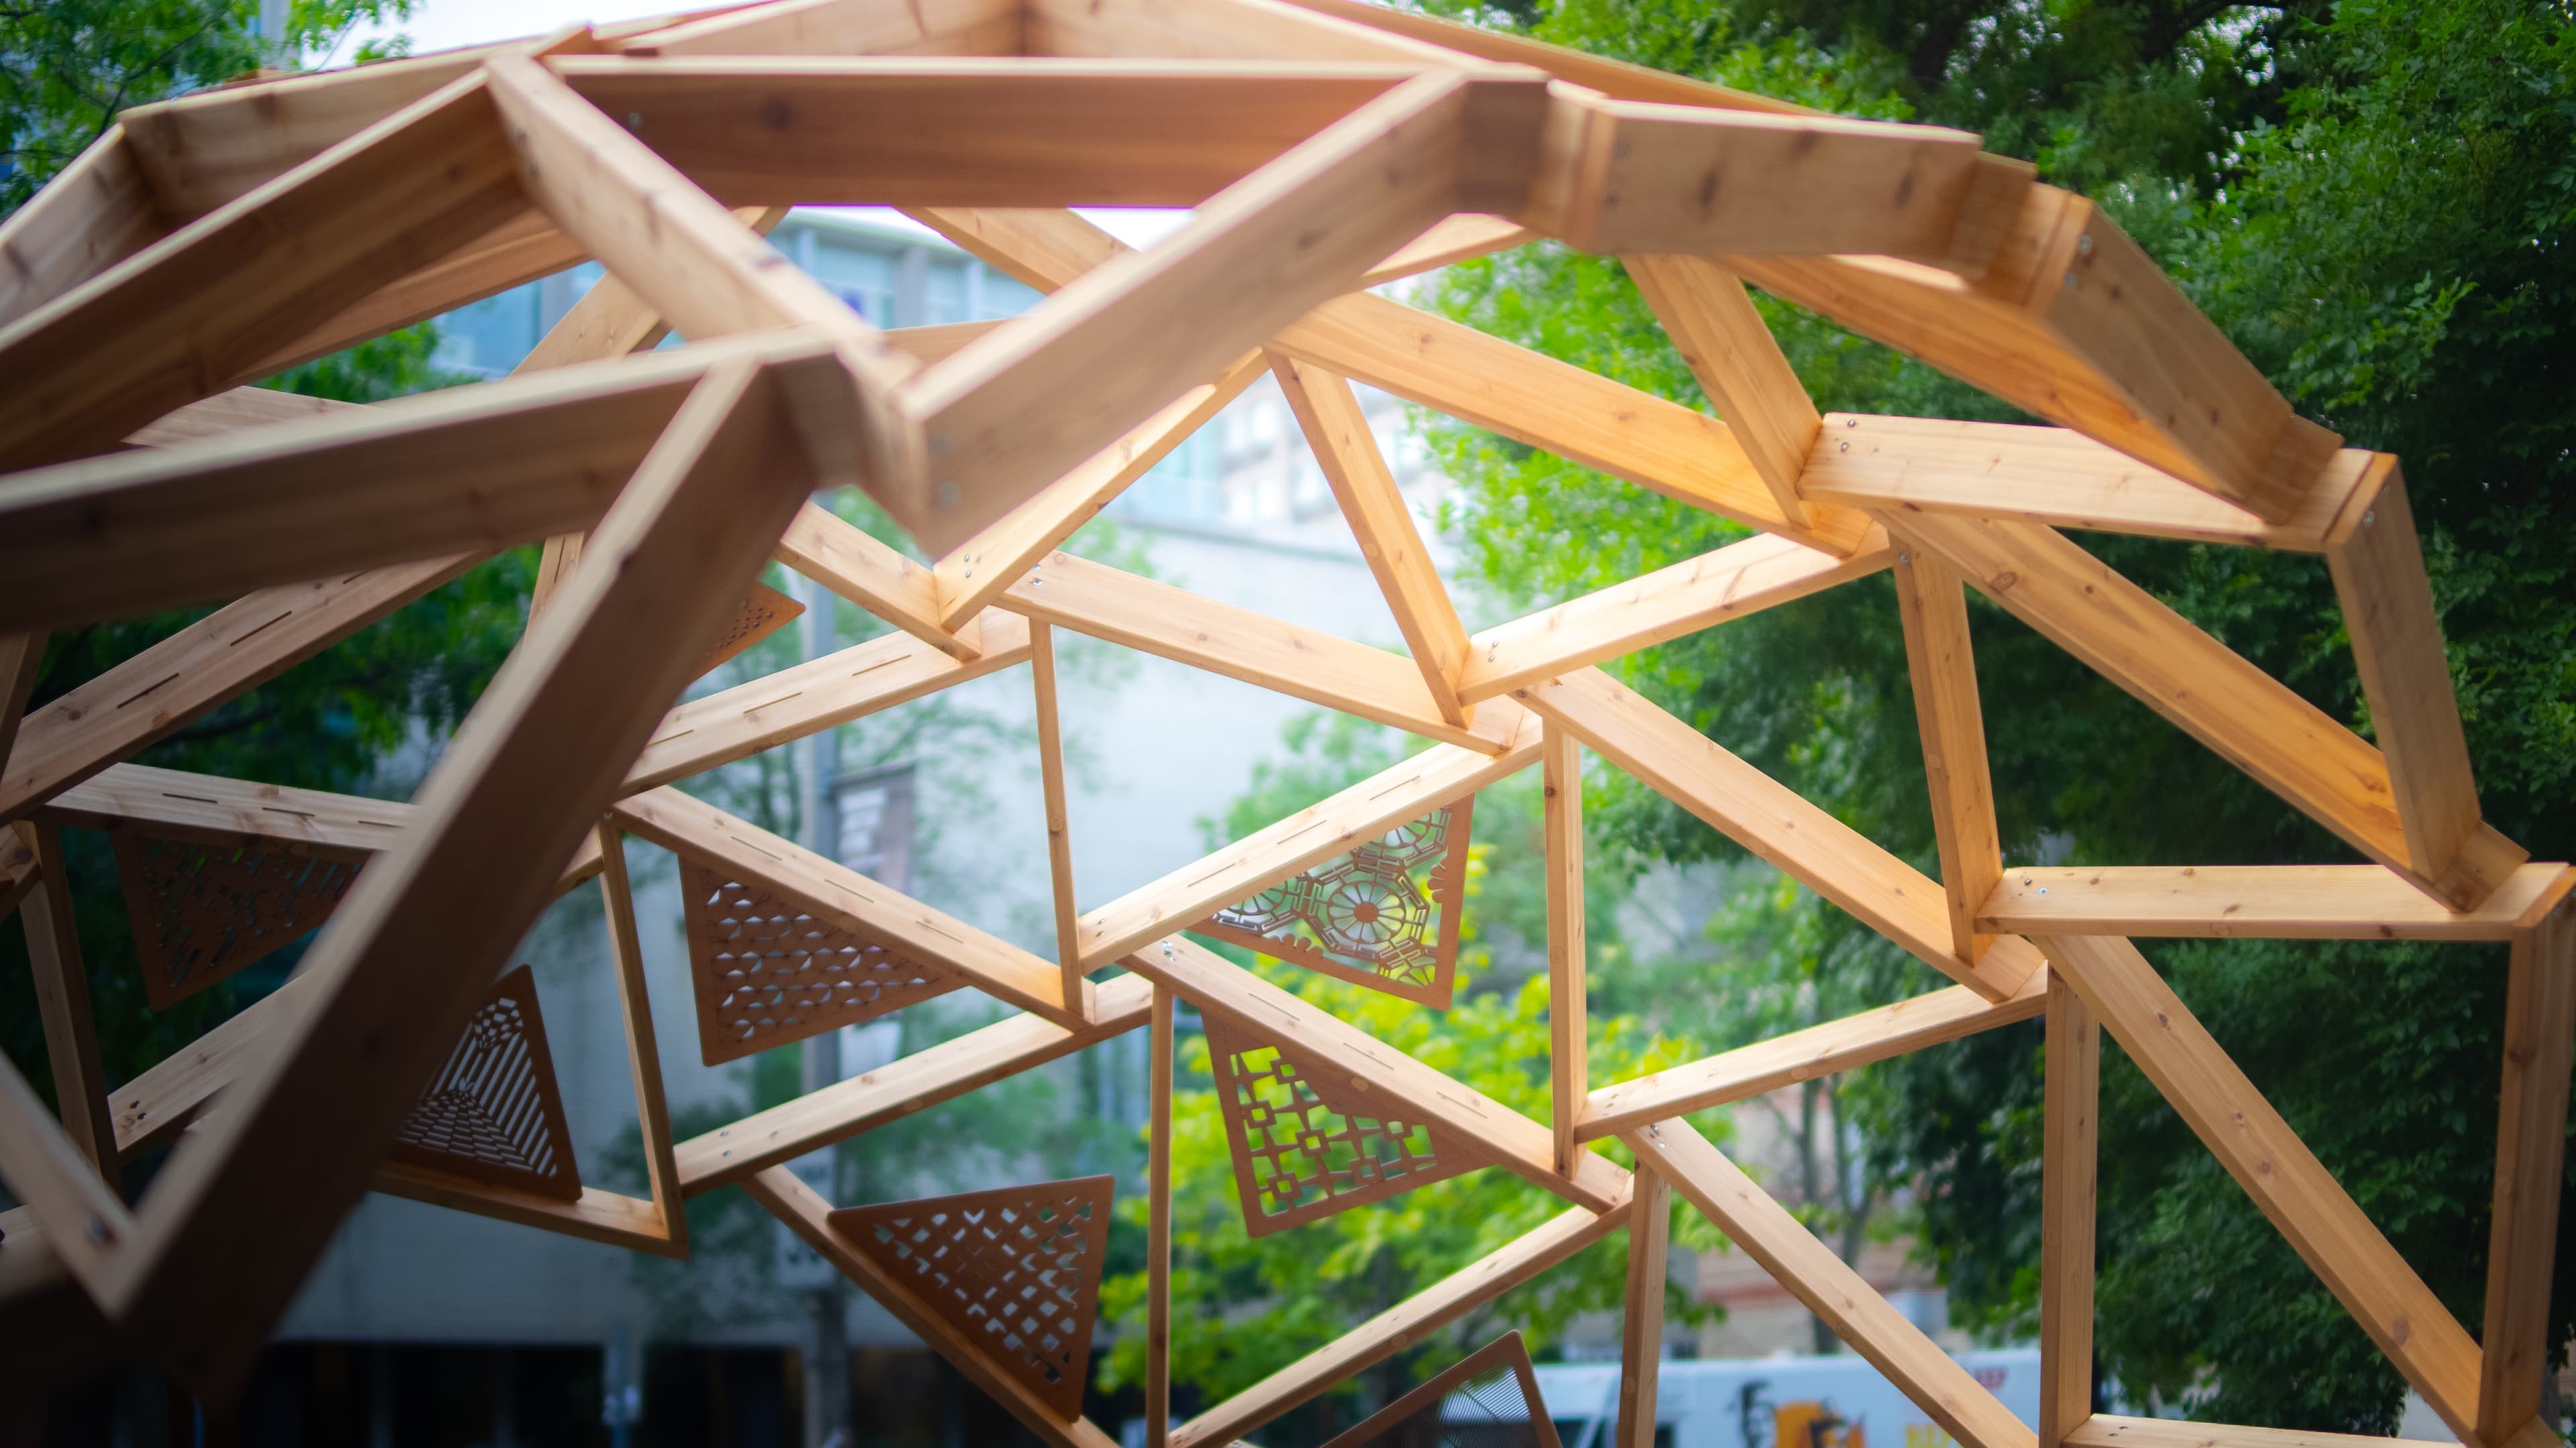
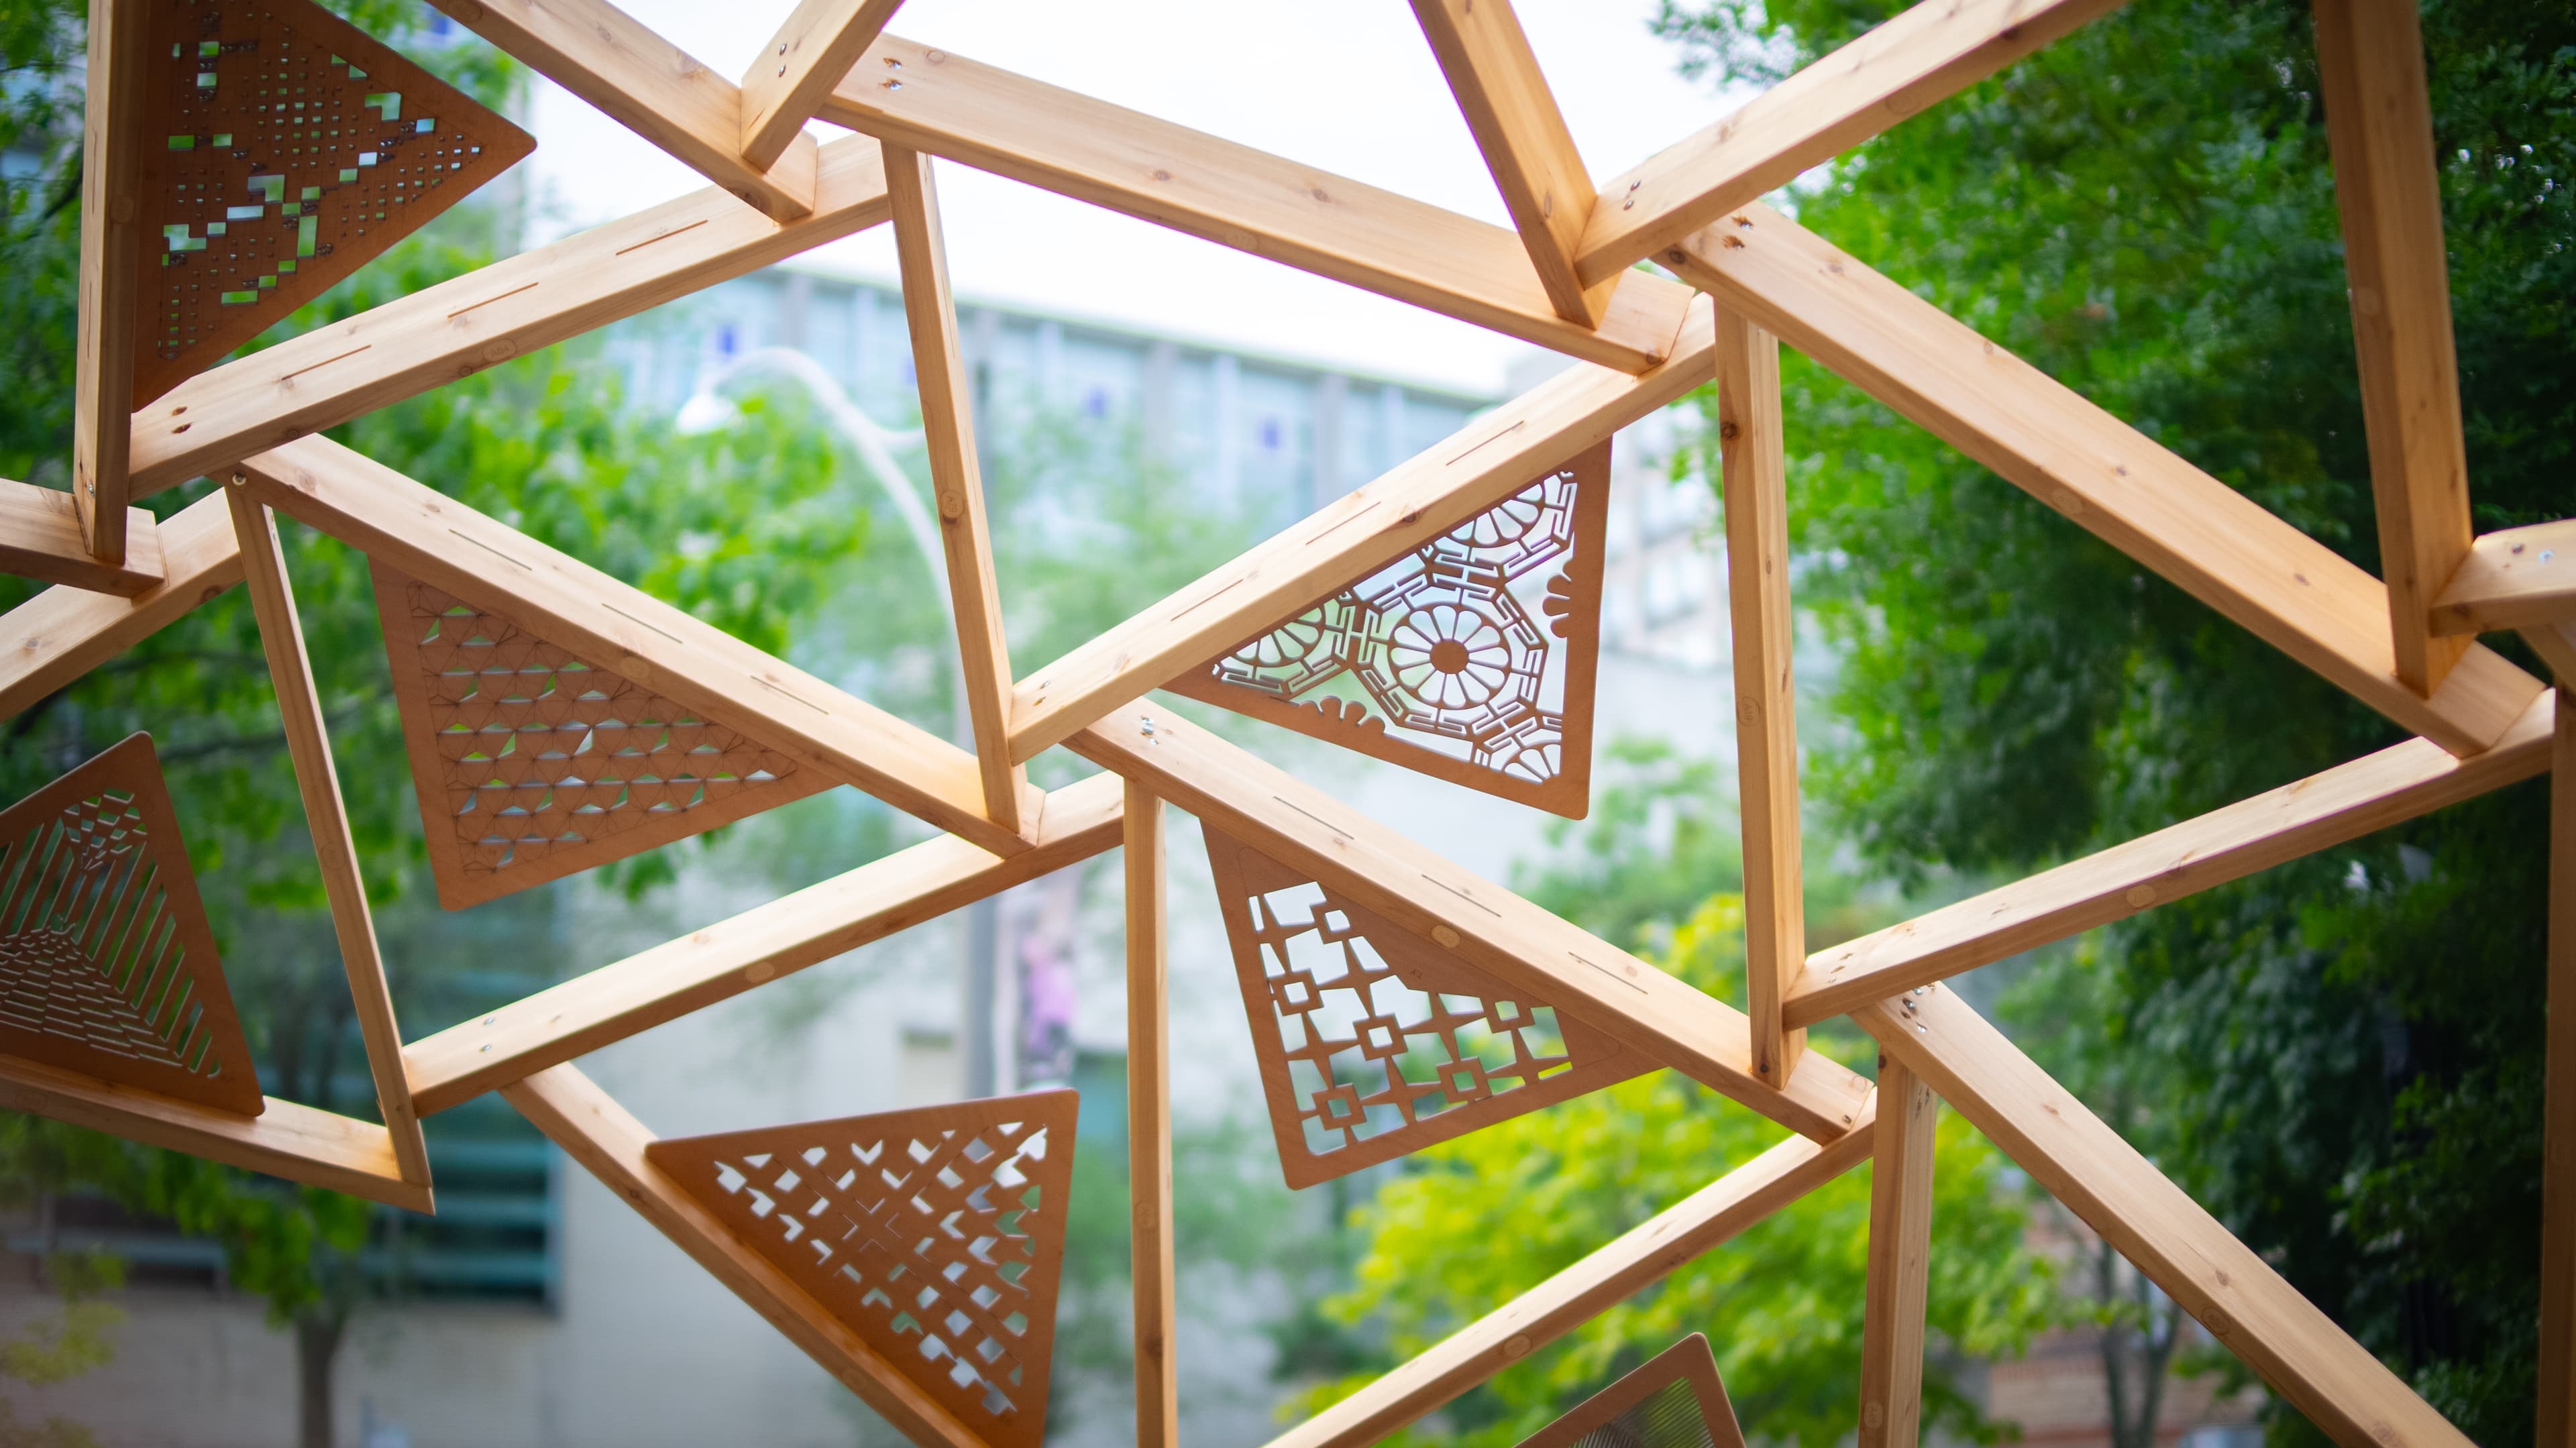
The pavilion was developed through parametric design, CNC processing, and industrial robotic fabrication, translating a digital structural system directly into bespoke timber components.
The final structure consisted of 110 unique timber elements designed for rapid, measurement-free assembly and scaffold-free construction.
02
My Role
Teaching Assistant
I supported students throughout the workshop across computational workflows, robotic fabrication, component production, and full-scale assembly, helping move the project from digital geometry to physical construction.
03
Credits
Project Leads
Nicholas Hoban
Aryan Rezaei Rad
Teaching Assistant
Liam Cassano
Student Participants
Kenny Vo
Nathania Nagarajah
Tony Yang
Shannon Dacanay
Melina Elefteriadis
Elina Parkhomenko
Myriam Bobe
Micha Fairfax-Angod
Tilija Leskauskaite
Yagmur Ceylan
Habib Yosufi
Sydney Nguyen
Keira Fraser
Jack Simon
Ryan Yee
04
Fabrication + Assembly
The workshop moved continuously between robotic fabrication, component preparation, and full-scale construction.
05
Project Images
Fabrication, robotic production, and assembly from Robot Made 2025 at the University of Toronto.